Cody, a robot companion in the making
I’m designing a penguin-inspired robot to fetch socks on voice command: find them in the bedroom, reach under the bed, pick them up with its beak and drop them in a bin.
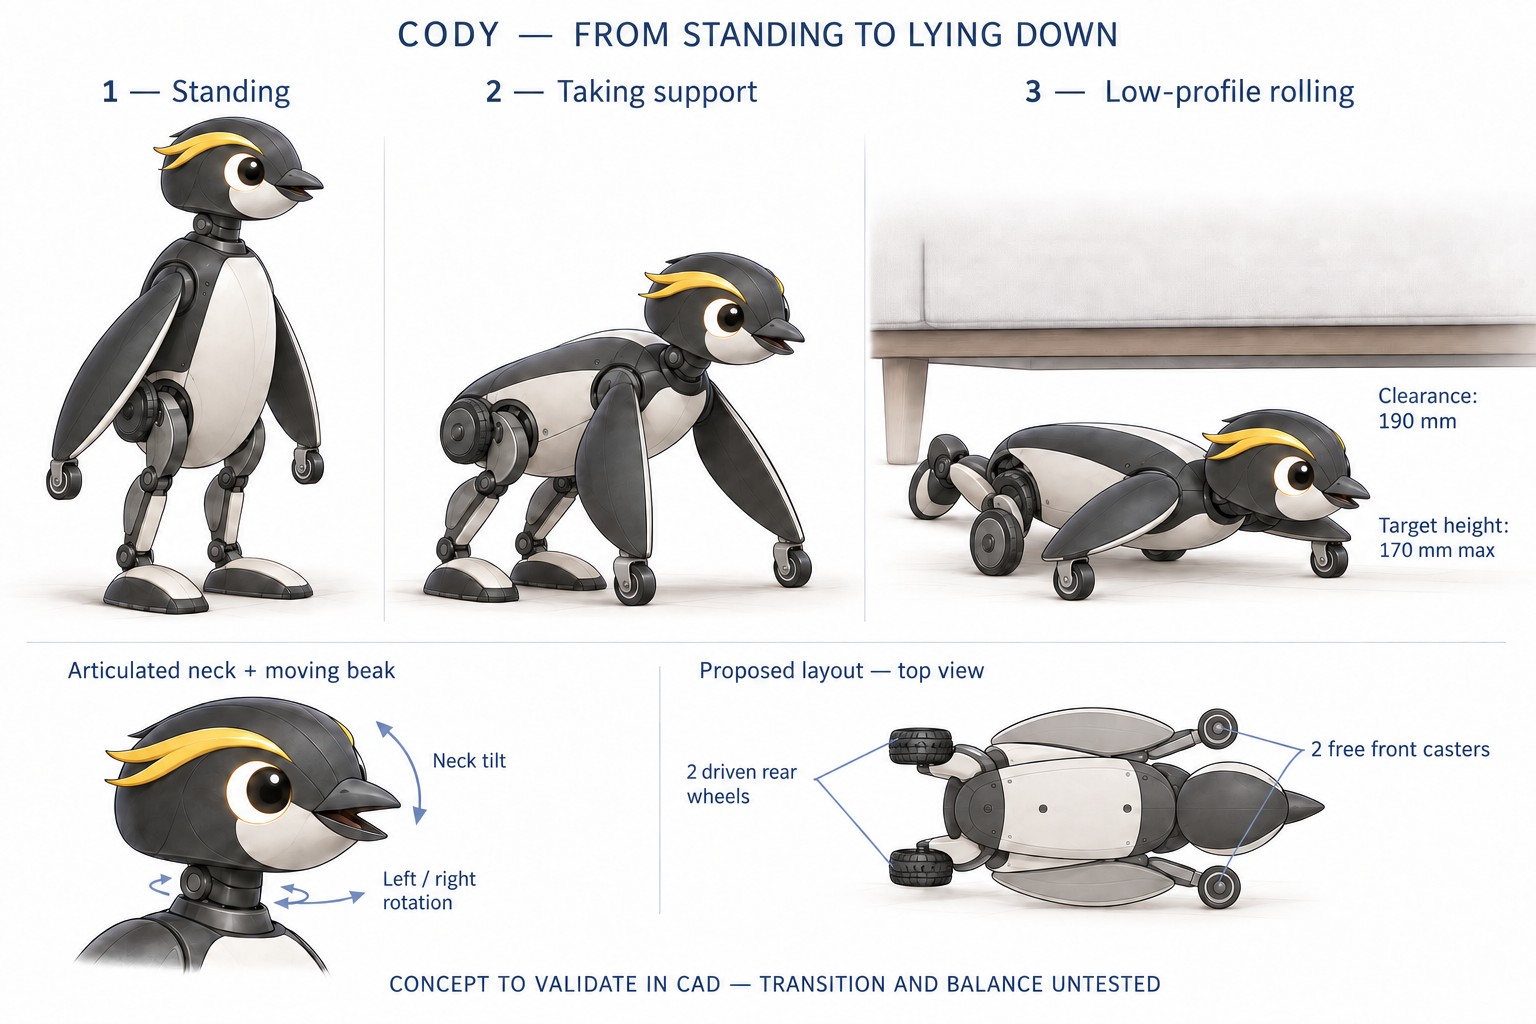
From concept to CAD
I based the leg mechanism on Pollen Robotics’ Microduck, working from images and its simulation model rather than native CAD source files. Through reverse engineering, I reconstructed and adapted the assembly with forward-facing knees, instead of Microduck’s backward-facing layout. I’m now resolving the internal layout around the battery and electronics. The low rolling posture still targets a 170 mm envelope beneath a 190 mm clearance.
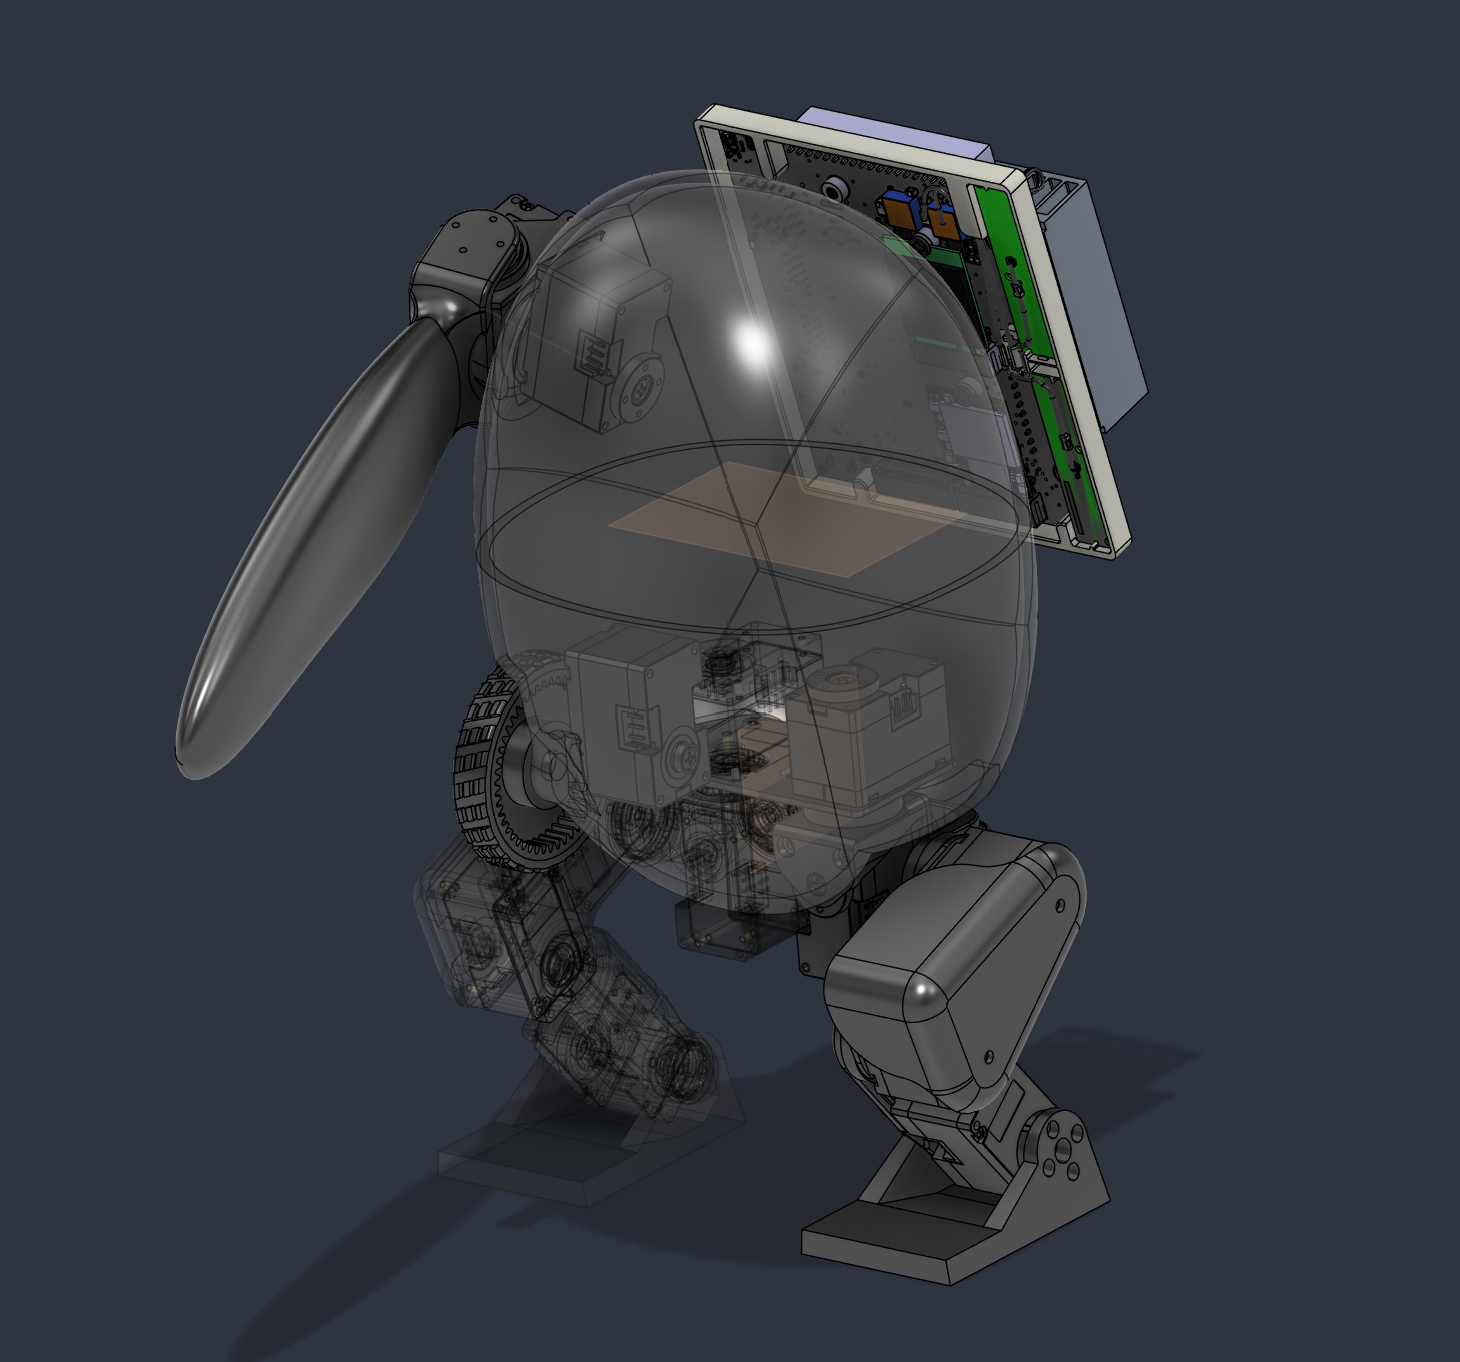
Design progress
Designed in CAD
- Shoulder and flipper architecture
- Both leg assemblies
- Wheel system architecture
- NVIDIA Jetson board placement
Still to do
- Body layout and component placement
- Neck and head design
- Beak mechanism
- Battery system selection and placement
Next milestone
Finalize the layout and battery system, then prepare the model for MuJoCo. Simulation, motor bench tests and the rest of the roadmap follow.